
About
I am an engineering student at the University of Toronto, fascinated by how complex behaviour emerges from simple rules, I value simplicity as the hard-won result of deep understanding. That philosophy carries through my interest in robotics, navigation, and motion planning — and into how I spend my spare time, climbing and designing mechanical puzzle boxes.
Inspired by my fascination with mechanical linkages and climbing, this interactive explores how simple geometry becomes elegant motion.
Technical Toolkit
Projects
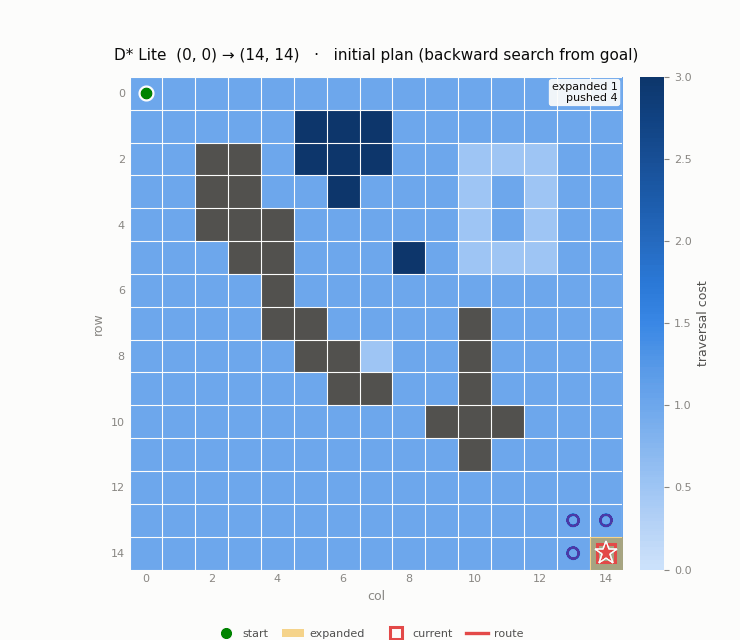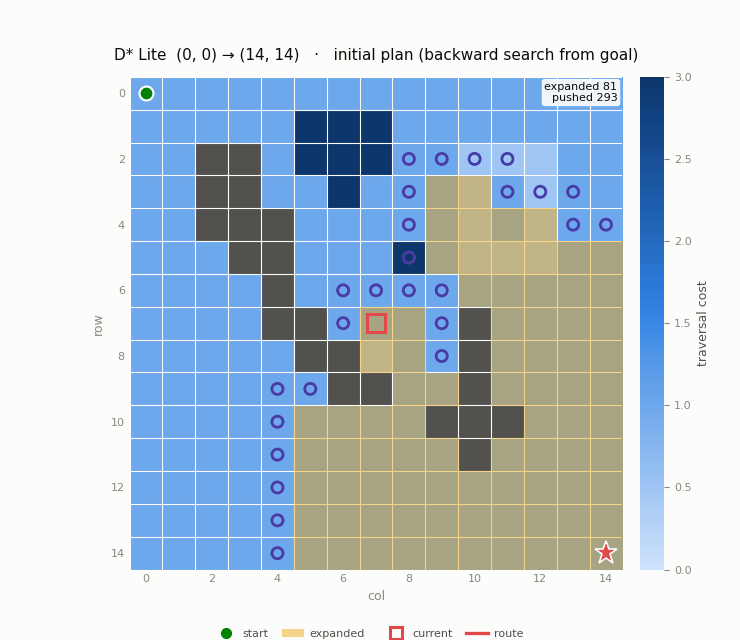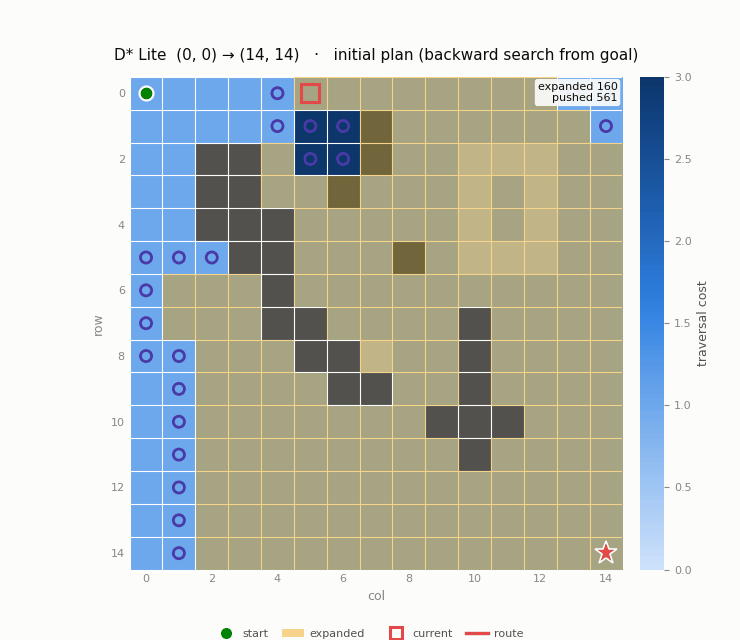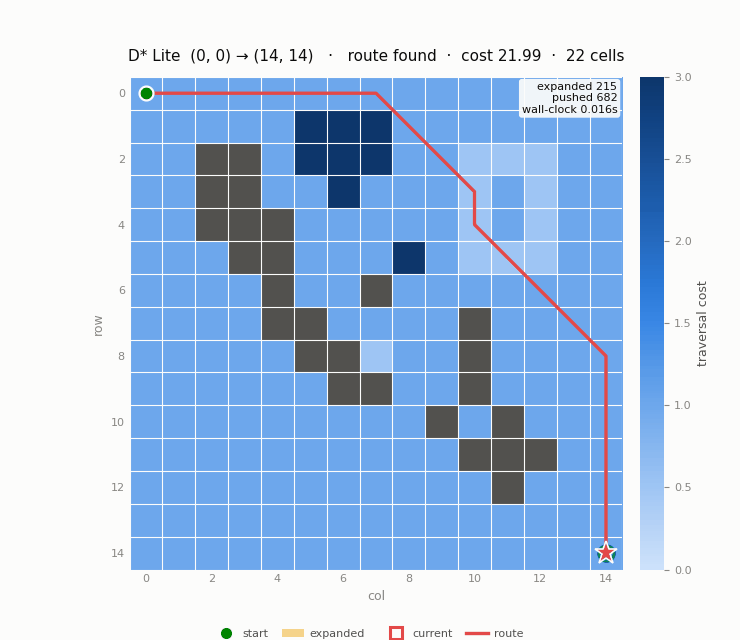
Incremental Path Replanning for Robot Navigation: A D* Lite Implementation and Benchmark
Built A* and D* Lite from scratch with custom priority queues, benchmarking them across 8 terrains and 4 scenarios to demonstrate a 35–42% reduction in node evaluations for incremental replanning (alongside wall-clock trade-off analysis). Extended the planner to a 2–3 robot multi-agent system using CBS-style constraints.
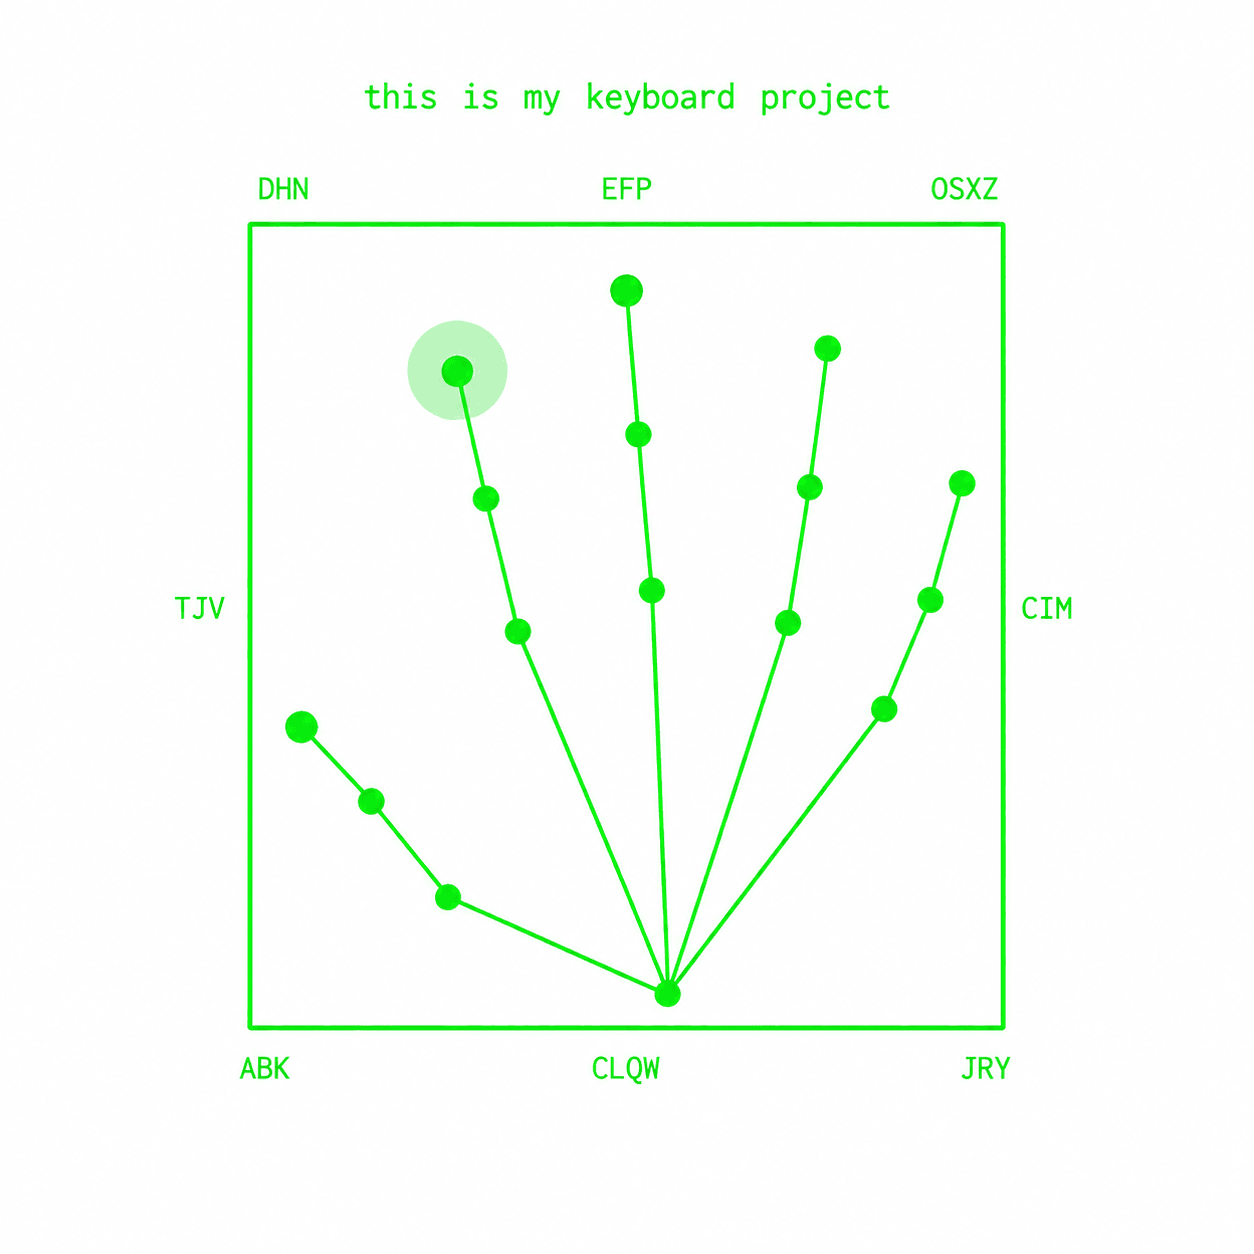
Invisible Keyboard for Assistive Accessibility
An AI-powered, touch-free gesture input system that utilizes Hidden Markov Models and Viterbi decoding to provide an intuitive alternative to traditional physical keyboards.
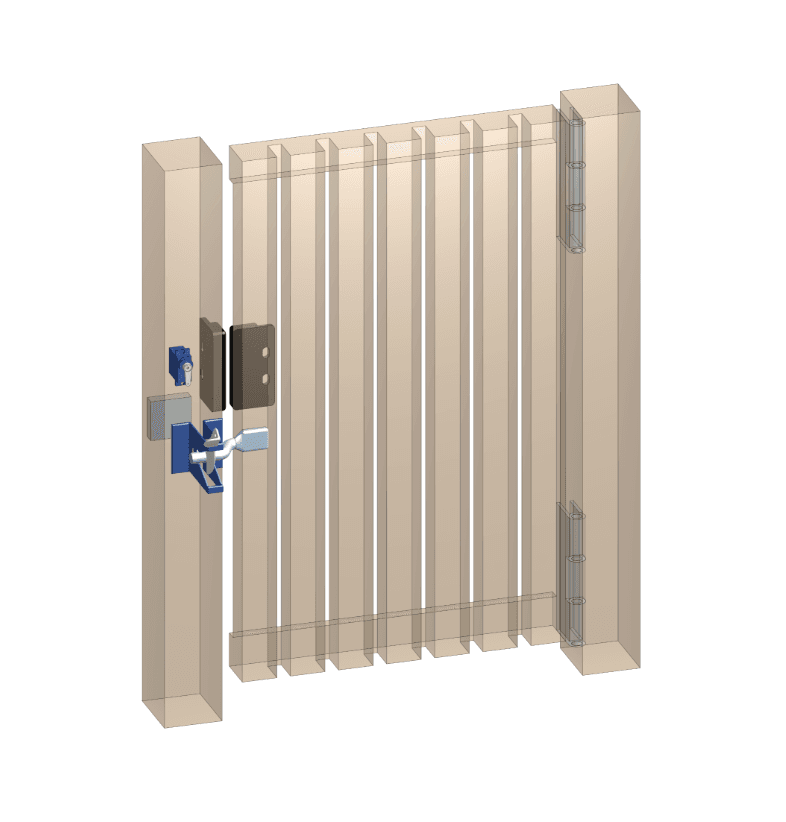
Child Safety Gate System: Multi-Stakeholder Hardware Design for Friends Daycare
Framed and co-designed a battery-powered staff wristband and servo-actuated gate system for a GTA daycare, applying stakeholder prioritization, steelmanning, and Pugh chart analysis to deliver a justified, evidence-backed solution that reduced staff supervision workload while maintaining child containment and independent parent access.
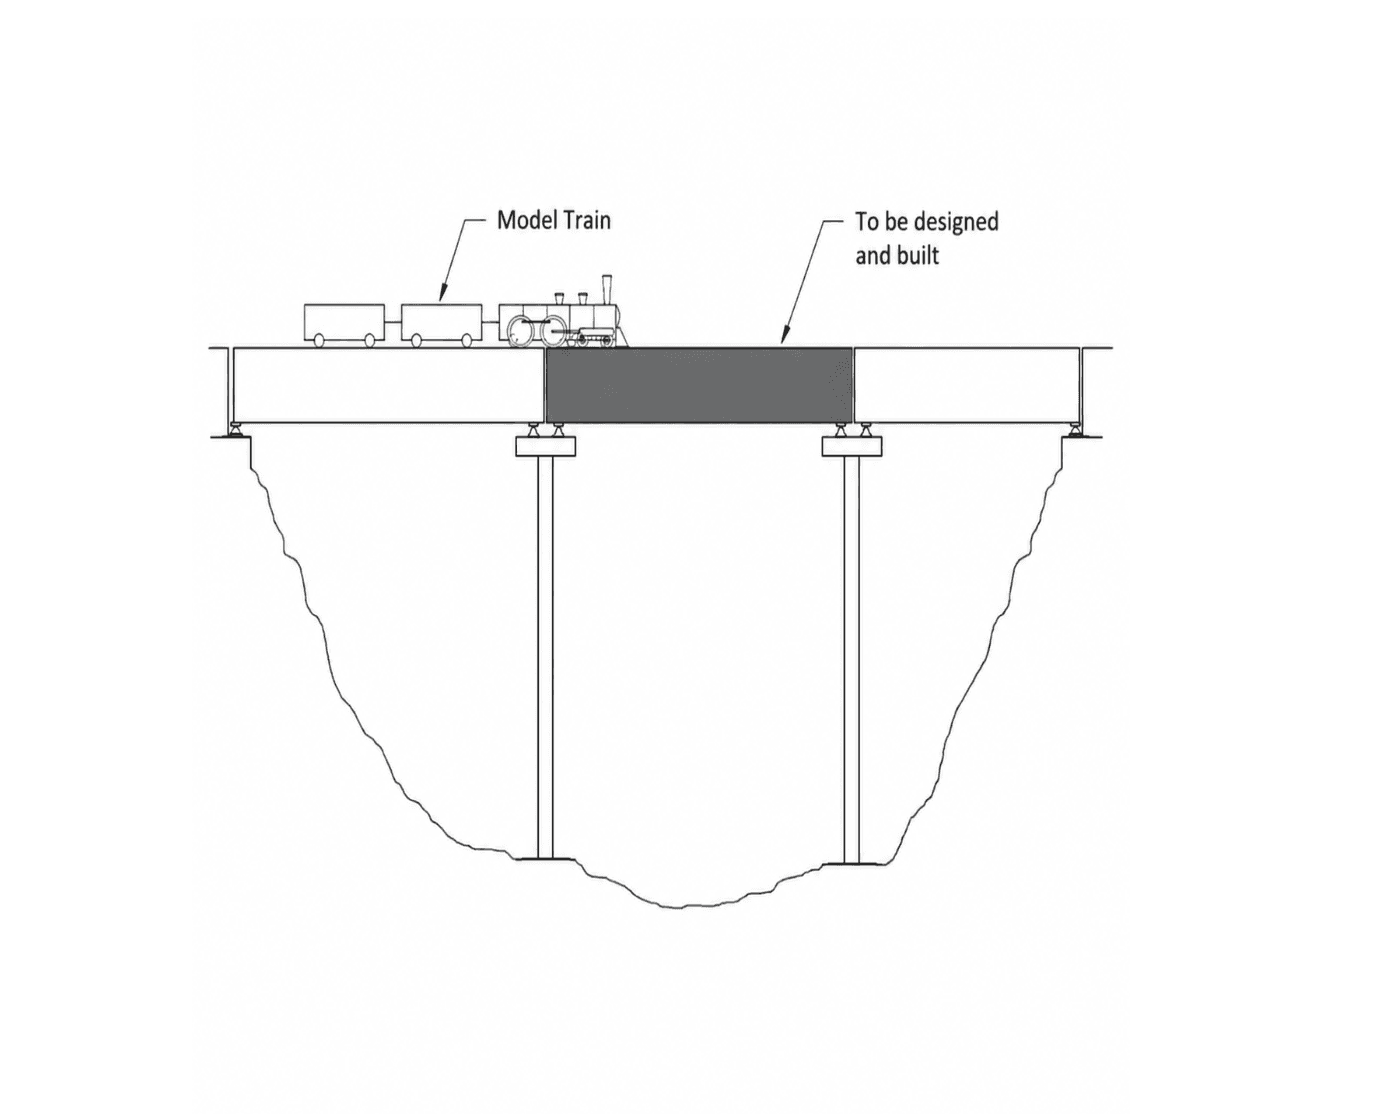
Matboard Beam Bridge: MATLAB Structural Simulation and Failure Analysis
Co-wrote a MATLAB simulation that modeled bending moment and shear force envelopes across a 1200 mm span, driving iterative cross-section optimization that improved the bridge factor of safety from 0.84 to 2.38. Then, I analyzed the gap between the 1092 N theoretical prediction and 133 N physical failure to uncover real-world splice failure modes.
Experience
Satellite Attitude Determination and Control System (ADCS) Member
University of Toronto Aerospace Team (UTAT) | Toronto, ON
May 2026 – Present
3 mos
Developing Python simulation software to validate satellite attitude determination and control systems by modeling high-fidelity sensor behaviors—including IMU, sun sensors, and magnetometers—and a Vispy 3D attitude visualization tool to replicate real-world space performance. This role involves research into orbital mechanics and advanced dynamics to drive accurate simulations for satellite operations.
Vice-President
Innvoire (STEM Nonprofit) | Mississauga, ON
Nov 2022 – Jun 2025
2 yrs 7 mos
Directed a student executive team in the end-to-end design and deployment of accessible STEM programming for 300+ youth. Successfully managed strategic corporate sponsorships, venue logistics, and partner outreach to drive organizational growth and program sustainability.
Academic Tutor
Safetynet Charities | Oakville, ON
Sep 2022 – Jun 2025
2 yrs 9 mos
Dedicated 100+ hours to supporting youth from low-income backgrounds by applying ADHD-informed pedagogical research and tailored learning strategies to bridge academic gaps. My approach focused on synthesizing complex concepts into accessible frameworks to foster resilience and long-term self-efficacy.
Awards
Chachra Family Scholarship in Engineering Science
$2,257.94
Awarded for strong academic achievement heading into second year of Engineering Science.
The Lo Family Scholarship
$5,000
Recognized for leadership and sustained community involvement throughout high school.
Governor General's Academic Medal
Non-monetary
Awarded for achieving the highest academic standing in a graduating high school class.
University of Waterloo Math & CS Scholarship
$12,000
Selected as one of 15 students nationally based on national mathematics competition performance.
Engineering Beyond the Classroom
See some of my hobbies! A few things I make and do outside of engineering — CAD, woodworking, art, and rock climbing among them.
See full gallery© 2026 Helen Huang